Paper Accepted in IEEE Transactions on Industrial Electronics
Our paper, "Reinforcement Learning Based Multi-Terrain Adaptive Whole-Body Control for a Quadruped Manipulator," has been accepted in IEEE Transactions on Industrial Electronics (TIE). We develop a learning-based whole-body controller that coordinates locomotion and manipulation across challenging terrains.
Paper Accepted in Advanced Intelligent Systems
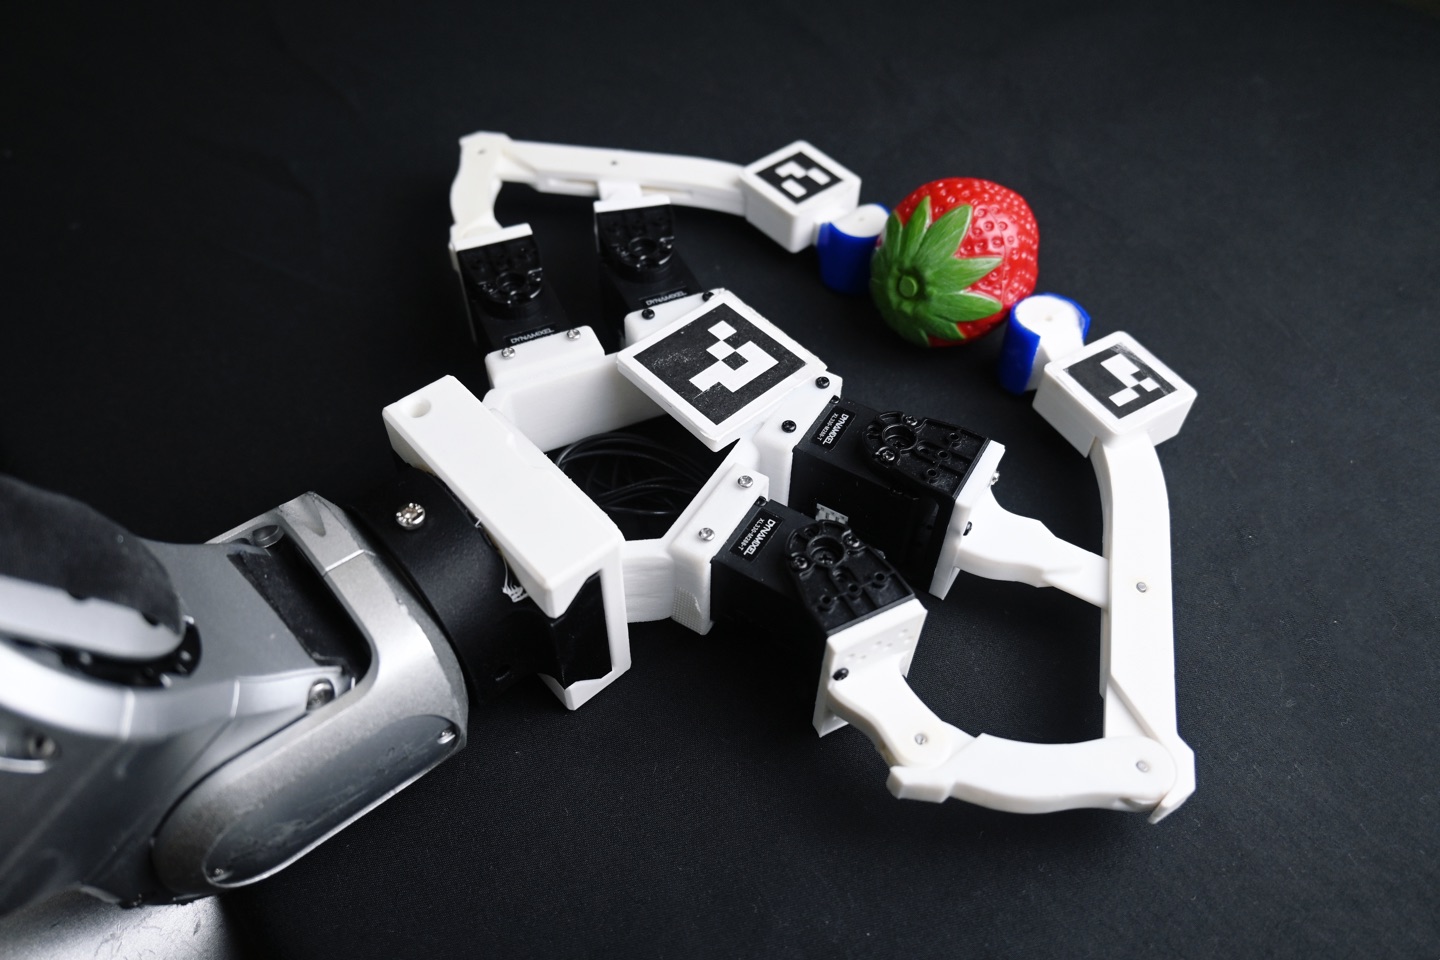
Our paper, "Reinforcement Learning With a Low-Cost Parallel Linkage Gripper for Static and Dynamic Planar In-Hand Manipulation," has been accepted in Advanced Intelligent Systems (AIS). We introduce D-PALI-E, a low-cost, 3D-printed parallel linkage gripper that learns static and dynamic in-hand manipulation skills.
Renewed Research Funding from the Nagamori Foundation
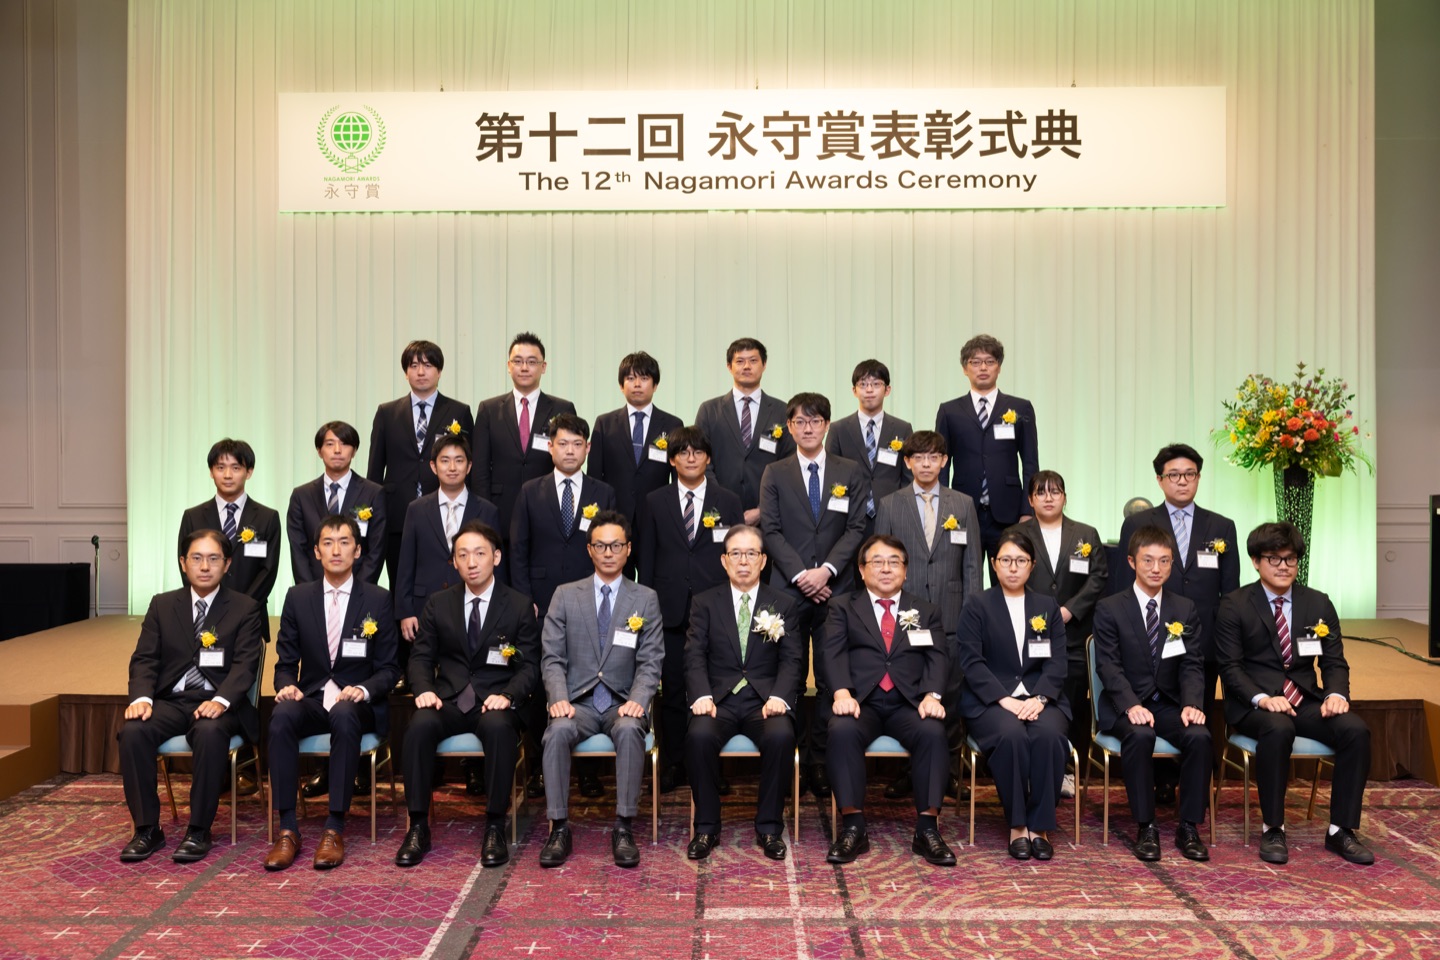
My project, "A General Purpose Exoskeleton for Teloperation based Robot Learning," received renewed funding from the Nagamori Foundation for 2026-2027. This support will help advance our research on teleoperation and robot learning.
JST SICORP CONCERT-Japan Kickoff Meeting at DLR
I attended the JST SICORP EIG CONCERT-Japan kickoff meeting at the German Aerospace Center (DLR) in Bonn, Germany, to launch and coordinate our international collaborative research activities.

Research Visit to TU Darmstadt
I visited the laboratory of Prof. Jan Peters at TU Darmstadt, Germany, to discuss robot learning, embodied intelligence, and future research collaborations.


ICRA 2026 Workshop: Robotic and AI for Aging
We organized the ICRA 2026 workshop on Robotic and AI for Aging, bringing together researchers to discuss how robotics and artificial intelligence can support healthy, independent, and inclusive aging societies.

Selected for JST PRESTO Sakigake
My research project was selected for the JST PRESTO Sakigake program and is listed in the AIP Network Co-Lab.


Research Grant Awarded by the Nagamori Foundation
My research project received funding from the Nagamori Foundation to advance teleoperation-based robot learning and embodied robotic systems.

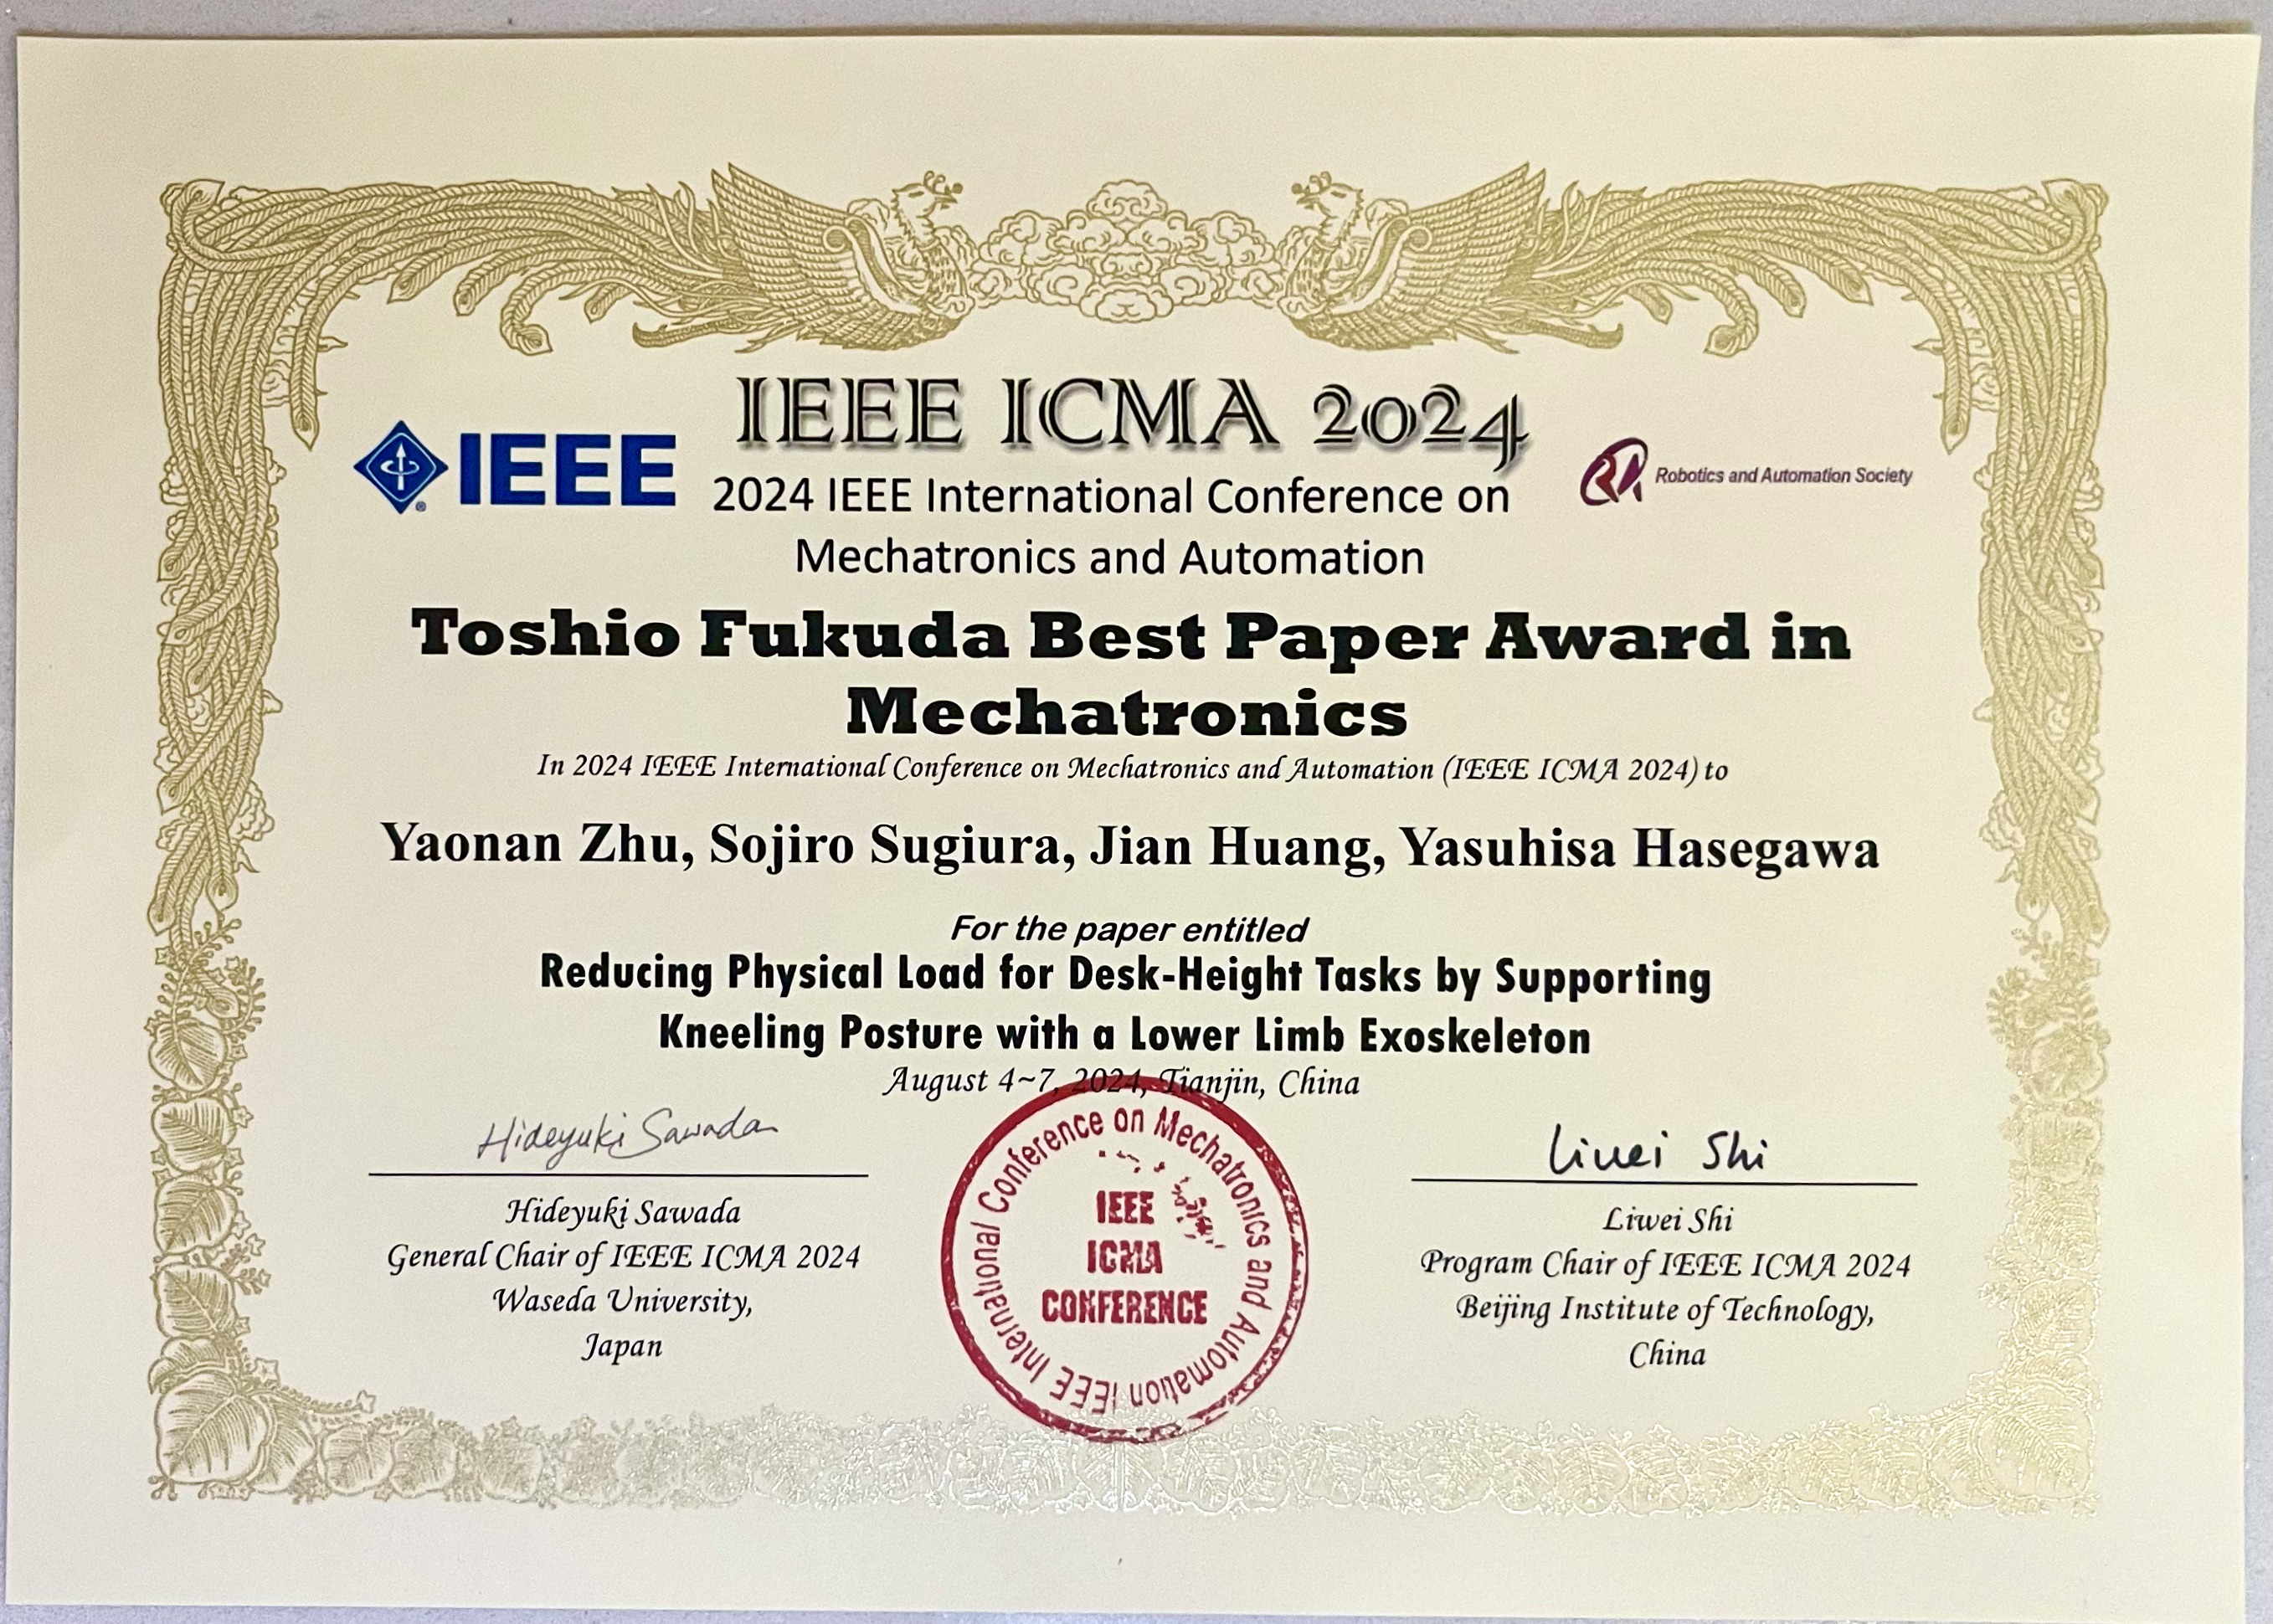
Best Paper Award at IEEE ICMA 2024
We received a Best Paper Award at the IEEE International Conference on Mechatronics and Automation (ICMA 2024).